RCTHB02 是一款基于 NVIDIA THOR 超级芯片平台打造的高性能通用人形机器人大脑控制器。它将超大规模 AI 算力、多模态传感器融合接口与 NVIDIA Isaac 机器人软件栈高度集成于紧凑的嵌入式控制器,专为人形机器人、通用具身智能体、工业双臂协作机器人、巡检机器人及下一代服务机器人等高端智能机器人量身设计。 RCTHB02 is a high-performance general-purpose humanoid-robot brain controller built on the NVIDIA THOR super-chip platform. It packs massive AI compute, multimodal sensor-fusion interfaces and the NVIDIA Isaac robotics software stack into a compact embedded controller — purpose-built for humanoid robots, general embodied agents, industrial dual-arm collaborative robots, inspection robots and next-generation service robots.
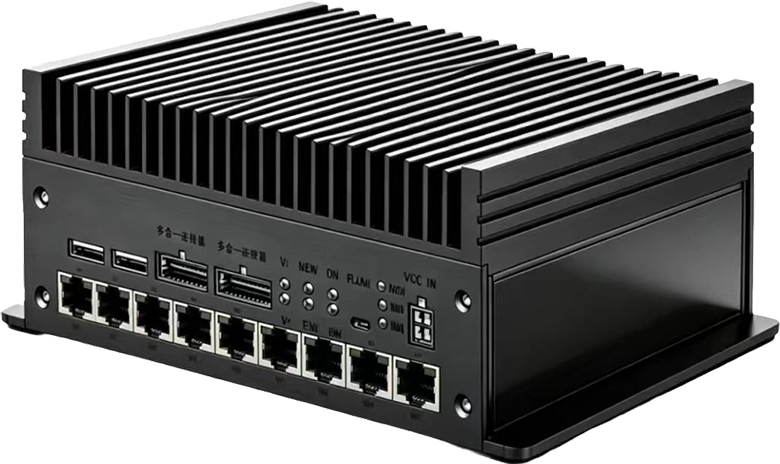
超级芯片平台提供超大规模 AI 算力,胜任人形机器人实时感知、决策与运动规划。A super-chip platform with massive AI compute for real-time perception, decision-making and motion planning in humanoids.
12 路 GMSL2 视频输入、万兆光口等,海量传感器高速接入,支撑多相机融合。12× GMSL2 video-in, 10GbE optical and more — high-speed ingest for heavy multi-sensor fusion.
预置 NVIDIA Isaac 机器人软件栈,从仿真到部署加速闭环,缩短开发周期。Preloaded NVIDIA Isaac stack accelerates the sim-to-deploy loop and shortens development cycles.
| 接口类型Interface | 数量Qty | 功能Function | 内部芯片Chip | 连接器Connector |
|---|---|---|---|---|
| 以太网 GbE | 4 | 工业以太网 | Switch | RJ45 |
| EtherCAT | 4 | EtherCAT | Switch | RJ45 |
| 万兆以太网 | 1 | 10GbE | PHY | 光口 |
| 视频输入 | 12 | GMSL2 | SOC | Fakra |
| 视频输出 | 2 | 显示输出 | SOC | - |
| USB | 4 | USB2.0 / 3.0 / 3.1 Host | SOC | USB3.0 |
| M.2 KEY M | 1 | 扩展存储 | SOC | 内部 |
| RTC | 1 | 实时时钟 | SOC | - |
| GNSS | 1 | 选配 | SOC | - |
| WIFI | 1 | 选配 | SOC | - |
| 蓝牙 | 1 | 选配 | SOC | - |
| 4G | 1 | 选配 | SOC | - |
| 5G | 1 | 选配 | SOC | - |
| IMU | 1 | 选配 | SOC | - |
| 音频输入 | 1 | 选配 | SOC | - |
| 音频输出 | 1 | 选配 | SOC | - |
| CAN FD | 6 | - | SOC | 48PIN-CMC |
| RS232 | 2 | 其中 1 路用于 Debug | SOC | 48PIN-CMC |
| RS485 | 4 | - | SOC | 48PIN-CMC |
| PWM | 6 | - | SOC | 48PIN-CMC |
| I/O | 10 | - | SOC | 48PIN-CMC |
| PWR | 1 | 电源 | SOC | 48PIN-CMC |